ai training data

Auto Added by WPeMatico

LLM Training Data

LLM Training Data: What Happens Between Off-the-Shelf and Production-Ready

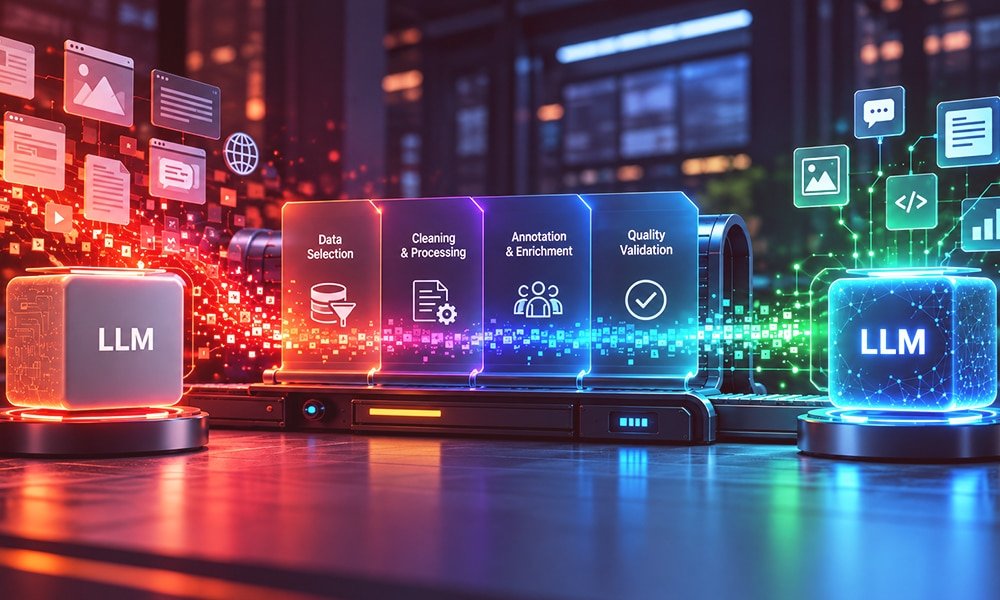
Buying a dataset takes a purchase order. Making it trainable takes a pipeline. The gap between those two states is where most LLM programmes lose their first month, and it is almost never discussed in the listing that sold the data. An off-the-shelf corpus is a starting position, not a finished input. It arrives with

LLM Training Data: What Happens Between Off-the-Shelf and Production-Ready Read More »
The Real Cost of AI Hasn’t Shown Up Yet

I realize I am dating myself to some extent, but my first cell phone plan came with a fixed number of minutes and a small allotment of text messages, and anything beyond that was billed one at a time. You […] The post The Real Cost of AI Hasn’t Shown Up Yet appeared first on

The Real Cost of AI Hasn’t Shown Up Yet Read More »

Synthetic vs Real-World Data

Synthetic vs Real-World Data for Robotics: Which to Buy for Your Physical AI Project

In physical AI, the model is rarely the bottleneck — the data is. A robot policy that runs flawlessly in a demo and then stalls in a live warehouse almost always fails on the data it never saw, not the architecture. That puts a budget question in front of every robotics team: when you decide

Synthetic vs Real-World Data for Robotics: Which to Buy for Your Physical AI Project Read More »

Robot Training Data

How Robot Training Data and Manipulation Datasets Power Real-World Robotics in 2026

Most robotics models work flawlessly in the demo and fall apart in deployment. The reason is almost never the architecture — it’s the data. A policy trained on staged tabletops and predictable objects collapses the moment it sees a cluttered apartment or a real warehouse aisle. Closing that gap is what robot training data and

How Robot Training Data and Manipulation Datasets Power Real-World Robotics in 2026 Read More »

Robot Training Data Strategy

Robot Training Data Strategy: Teleoperation vs Simulation vs Human Video for Embodied AI

Building a robot policy that works in the real world isn’t a computer problem anymore — it’s a data problem. Embodied AI teams have three options for fueling their models: teleoperation, simulation, and human video. Each comes with a different cost curve, a different fidelity profile, and a different ceiling on what your robot can

Robot Training Data Strategy: Teleoperation vs Simulation vs Human Video for Embodied AI Read More »

Physical AI Dataset Stack

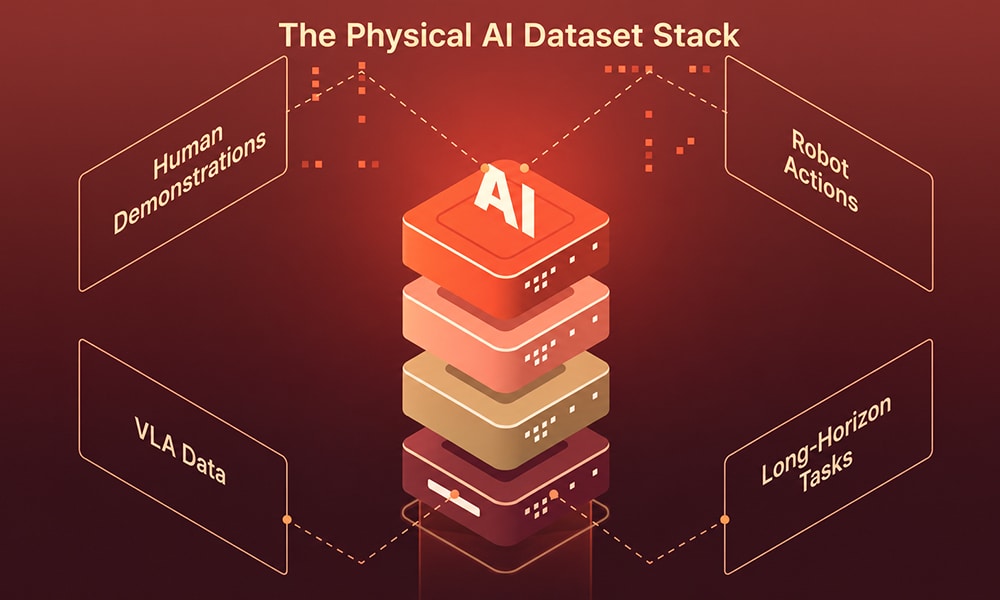
The Physical AI Dataset Stack: Human Demonstrations, Robot Actions, VLA Data, and Long-Horizon Tasks

Most physical AI teams know they need data. Few know they need a stack of it. The capabilities a deployed humanoid, AV, or warehouse robot needs — perception, action, instruction following, multi-step workflow execution — each map to a different layer of training data, with different collection methods, annotation depth, and quality controls. The physical

The Physical AI Dataset Stack: Human Demonstrations, Robot Actions, VLA Data, and Long-Horizon Tasks Read More »

Startup offers free home cleaning—if it can record it all for robot training

A tech startup is offering New York City residents free home cleaning with a twist—it will send “professional cleaners” wearing cameras to record everything they do. All that data will supposedly be used to train AI-driven robots. The unusual pitch comes from the German startup MicroAGI, whose website describes the company as a “team of

Startup offers free home cleaning—if it can record it all for robot training Read More »

VLA models

VLA Models: What Vision-Language-Action Models Need from Training Data

The shift from chatbots to robots that follow natural-language commands runs through a single class of models. VLA models — vision-language-action models — combine visual perception, language understanding, and action generation in one neural network. Their power is real, but it depends almost entirely on the training data they ingest. This guide explains what VLA

VLA Models: What Vision-Language-Action Models Need from Training Data Read More »

Tactile Sensing Data

Tactile Sensing Data: The Training Signal Behind Robots That Can Actually Feel

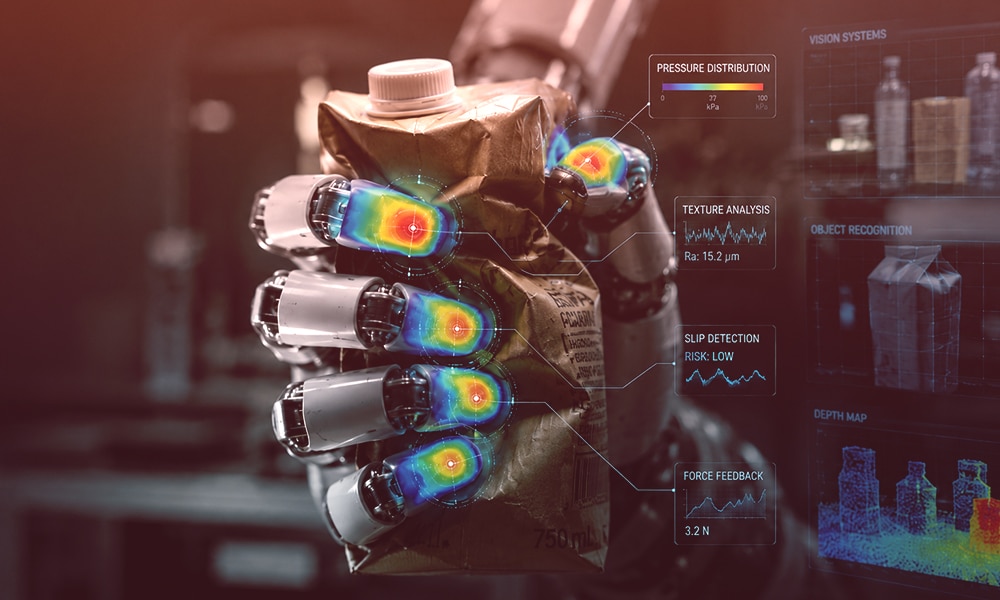
Robots can see. Internet-scale image datasets and a decade of refined models made that possible. But ask a robot to actually pick up a half-crushed carton, thread a cable, or hand a tool to a surgeon, and the wheels come off. Not because the cameras failed. Because nothing in the robot’s training ever taught it

Tactile Sensing Data: The Training Signal Behind Robots That Can Actually Feel Read More »

Robotics Data Annotation

How to Annotate Robotics Data: Objects, Actions, Intent, Motion, and Failure Modes

A robot that picks the wrong box, freezes in front of a person, or drops a fragile part rarely fails because of bad code. It fails because something it was taught to recognize wasn’t labeled correctly — or wasn’t labeled at all. Robotics data annotation is what stands between raw sensor streams and a robot

How to Annotate Robotics Data: Objects, Actions, Intent, Motion, and Failure Modes Read More »